Supported By: Texas Instruments (TI)
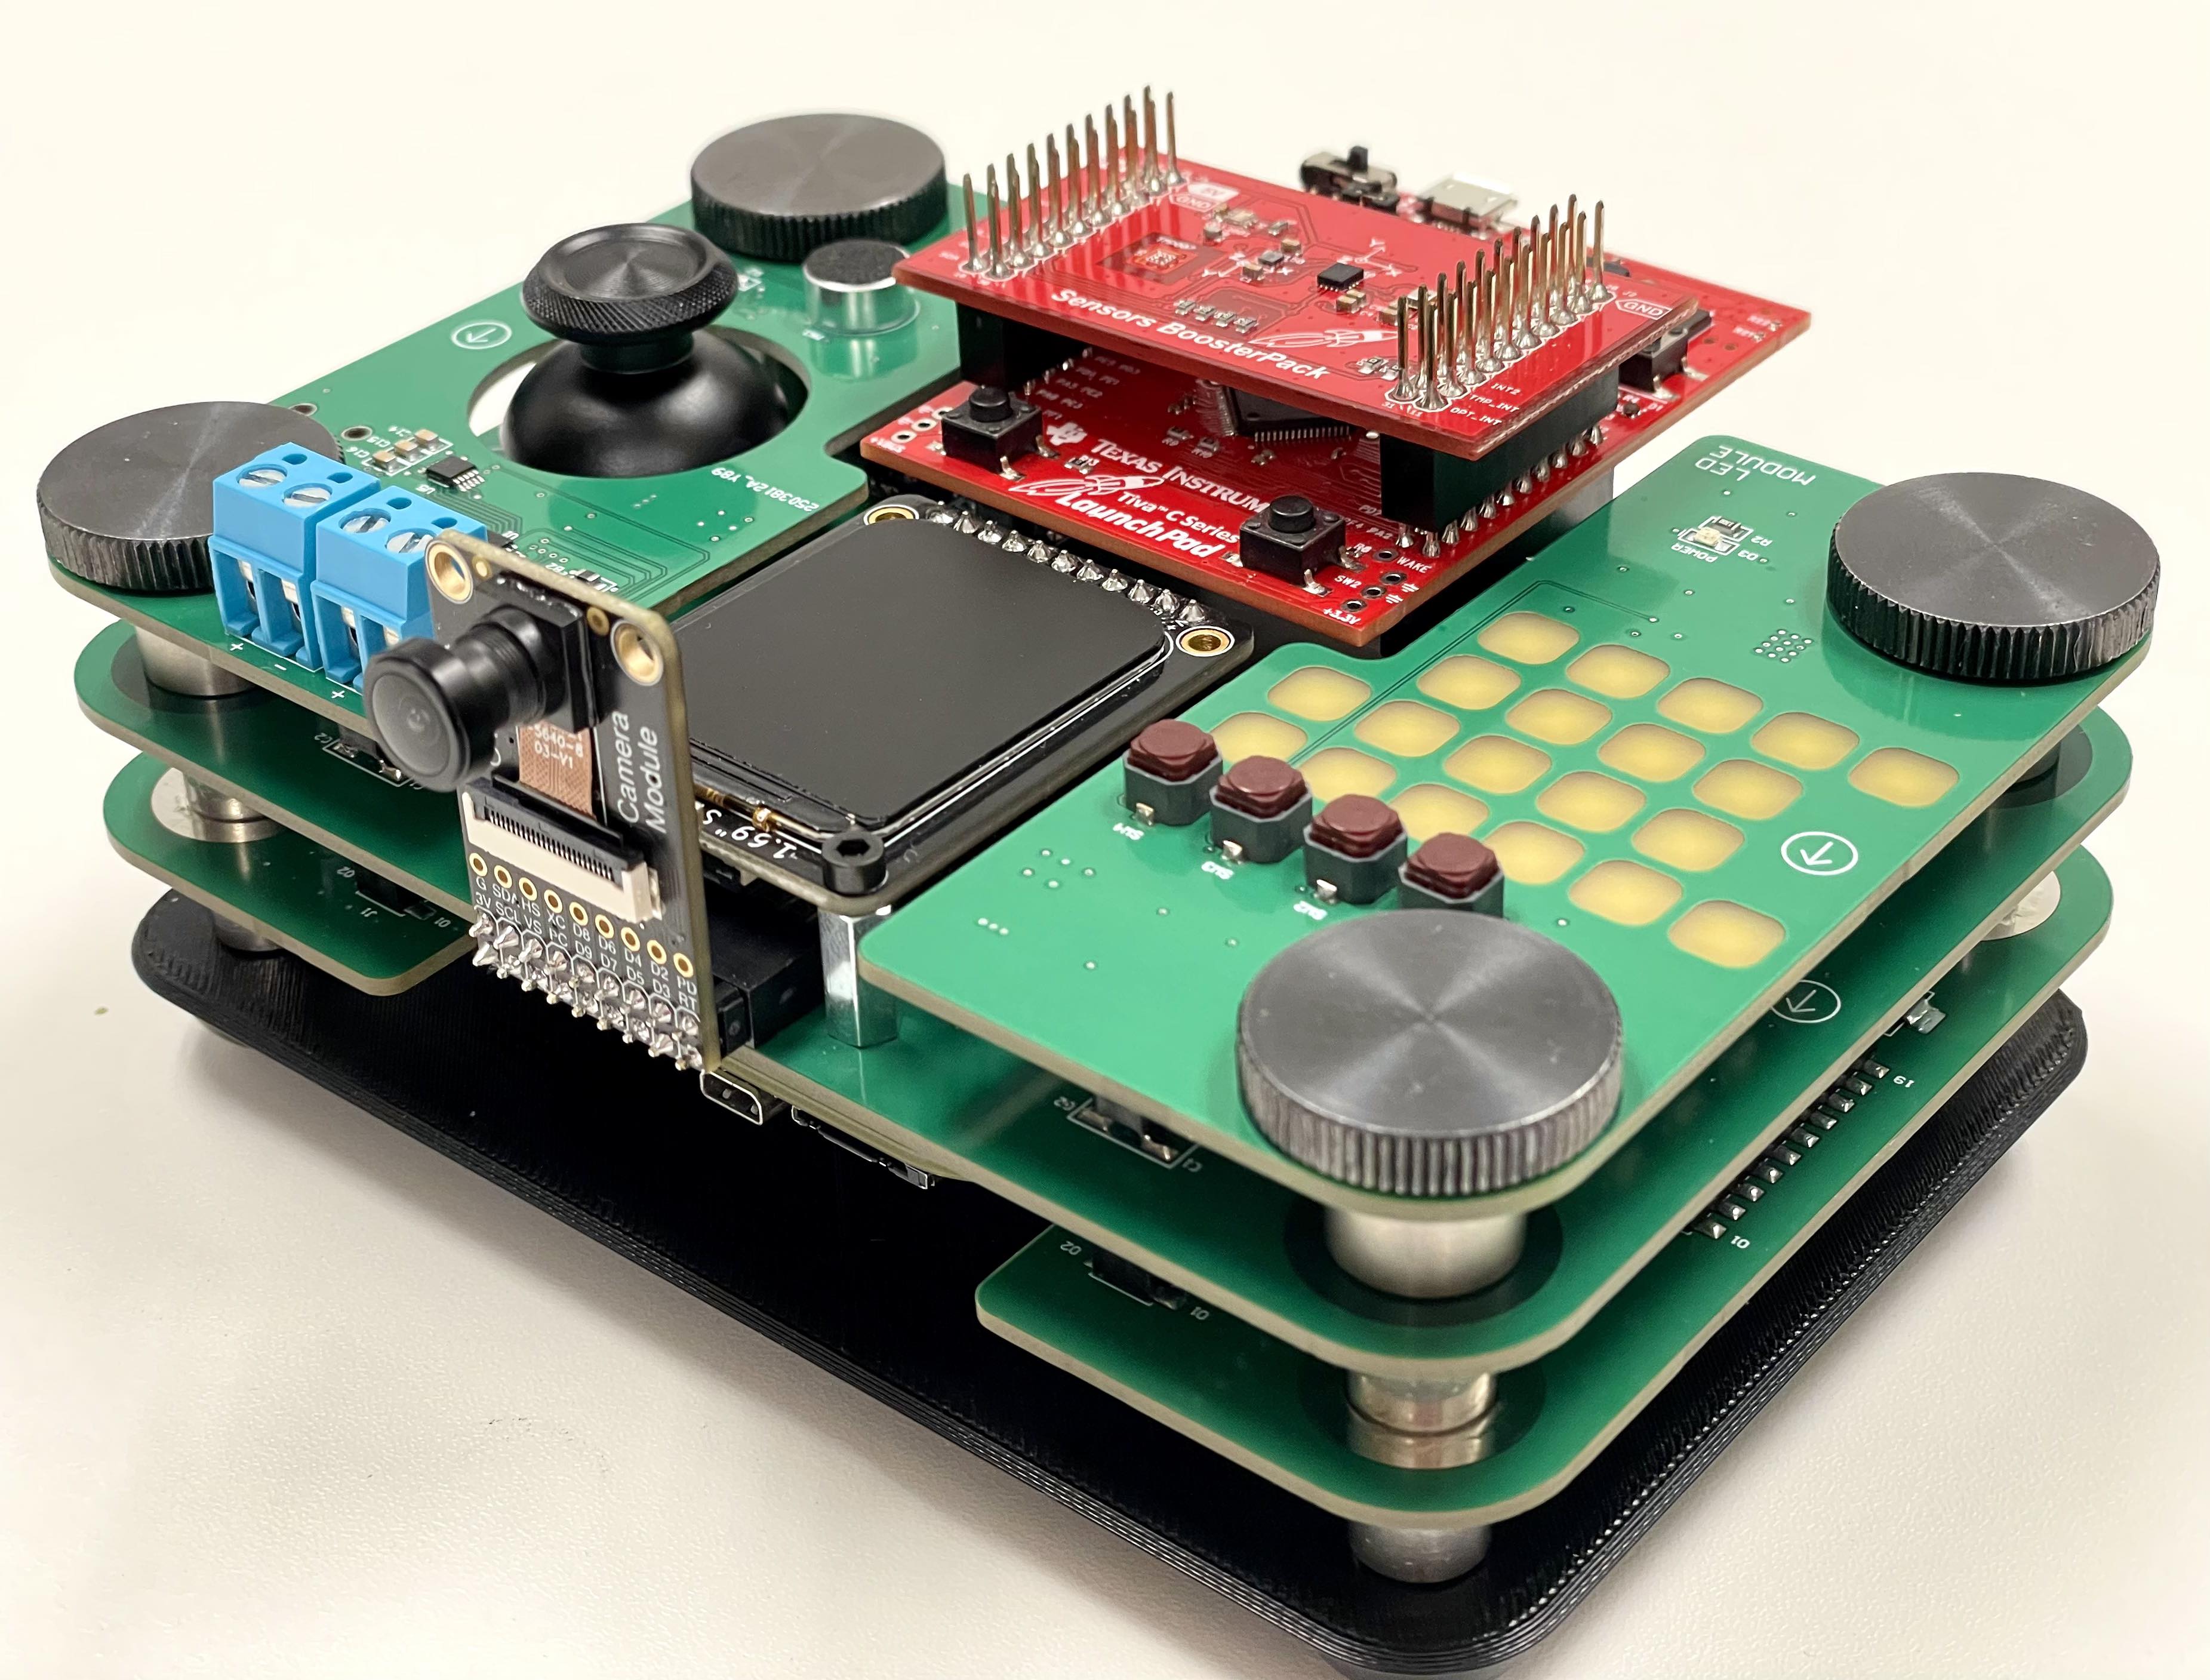
RTOS Platforms: Our New Daugtherboard.
| [Lab1] LED blinking and Console Interfacing (UART) 1 week |
|---|
|
Objectives: In this lab, you will blink LEDs on the Tiva Launchpad. You will also output messages using the UART module on the microcontroller and begin using the serial console embedded in the Code Composer Studio (CCS) IDE. The purpose of this lab is to get you used to the IDE, the microcontroller datasheet, and how to build and flash programs into the microcontroller.
Note: To choose which part to build, include that file in the project and exclude the other part by right-clicking on the file in the project explorer in CCS. See the walkthrough: https://youtu.be/k0EVFgi1knY. |
| [Lab2] I2C Communication, Timers, and Sensor Interfacing 2 weeks |
|---|
|
Objectives: In this lab, you will be creating I2C functions to utilize the I2C modules on the Tiva TM4C123GH6PM and using them to interface with sensors on the sensor booster pack. You will output these values and display them on a console (in CCS) using UART communication, and then use timers so that these values and messages are shown at specific rates.
|
| [Lab3] G8RTOS Scheduler and Synchronizers 3 weeks |
|---|
|
Objectives: Real-time operating systems (RTOS) are a fundamental part of embedded systems. They guarantee that certain blocks of code will run by using a very robust flow and allocation of execution time to different parts of a program that may not be guaranteed with sequentially designed code. The main objectives of this lab are to implement multiple threads for dedicated tasks, a scheduler for these threads, and a simple spin-lock semaphore primitive for synchronization.
|
| [Lab4] G8RTOS IPC, Dynamic Threads, Priority Scheduling 3 weeks |
|---|
|
Objectives: One of the core features of an RTOS relates to the utilization of threads. This requires an interface between system-level controls, such as the stack pointer, which is provided by select assembly functions. One must consider, however, that a few key things make the threads work as we want them to. The main objectives of this lab are to implement more fine-tuned control over the threads to enable them to communicate with each other, as well as give us hard guarantees of the scheduling order of threads. Walkthrough video: https://youtu.be/yDRkCWjt62c.
|
| [Lab5] On-device AI/AIoT with RTOS 1 week |
|---|
|
Objectives: In this lab, you will learn how to interface a (remote) communication protocol with RTOS. Several systems, including standard video surveillance cameras, remote inspection drones, and doorbell cameras, have very similar applications. For a simplified setup, you will use your laptop to stream a message through the (wired) network to your BeagleBone. Then, we will perform on-device data generation and interface the output on your multimod daughterboard.
|
| [Lab6] Real-Time Audio Signal Processing 2 weeks |
|---|
|
Objectives: In this lab, students will integrate Real-Time Operating Systems (RTOS) for Digital Signal Processing (DSP) using provided libraries and procedures to develop an efficient, real-time audio I/O application. Tone detection plays a vital role in digital signal processing, particularly in real-time audio applications such as DTMF. The Goertzel Algorithm is commonly implemented on resource-constrained devices for this purpose. This lab focuses on utilizing this algorithm to analyze the frequency components of audio signals, process them in real-time, and provide visual feedback on the display. This lab will also build on the topics from prior labs to simultaneously output tones via an onboard DAC based on user input.
|